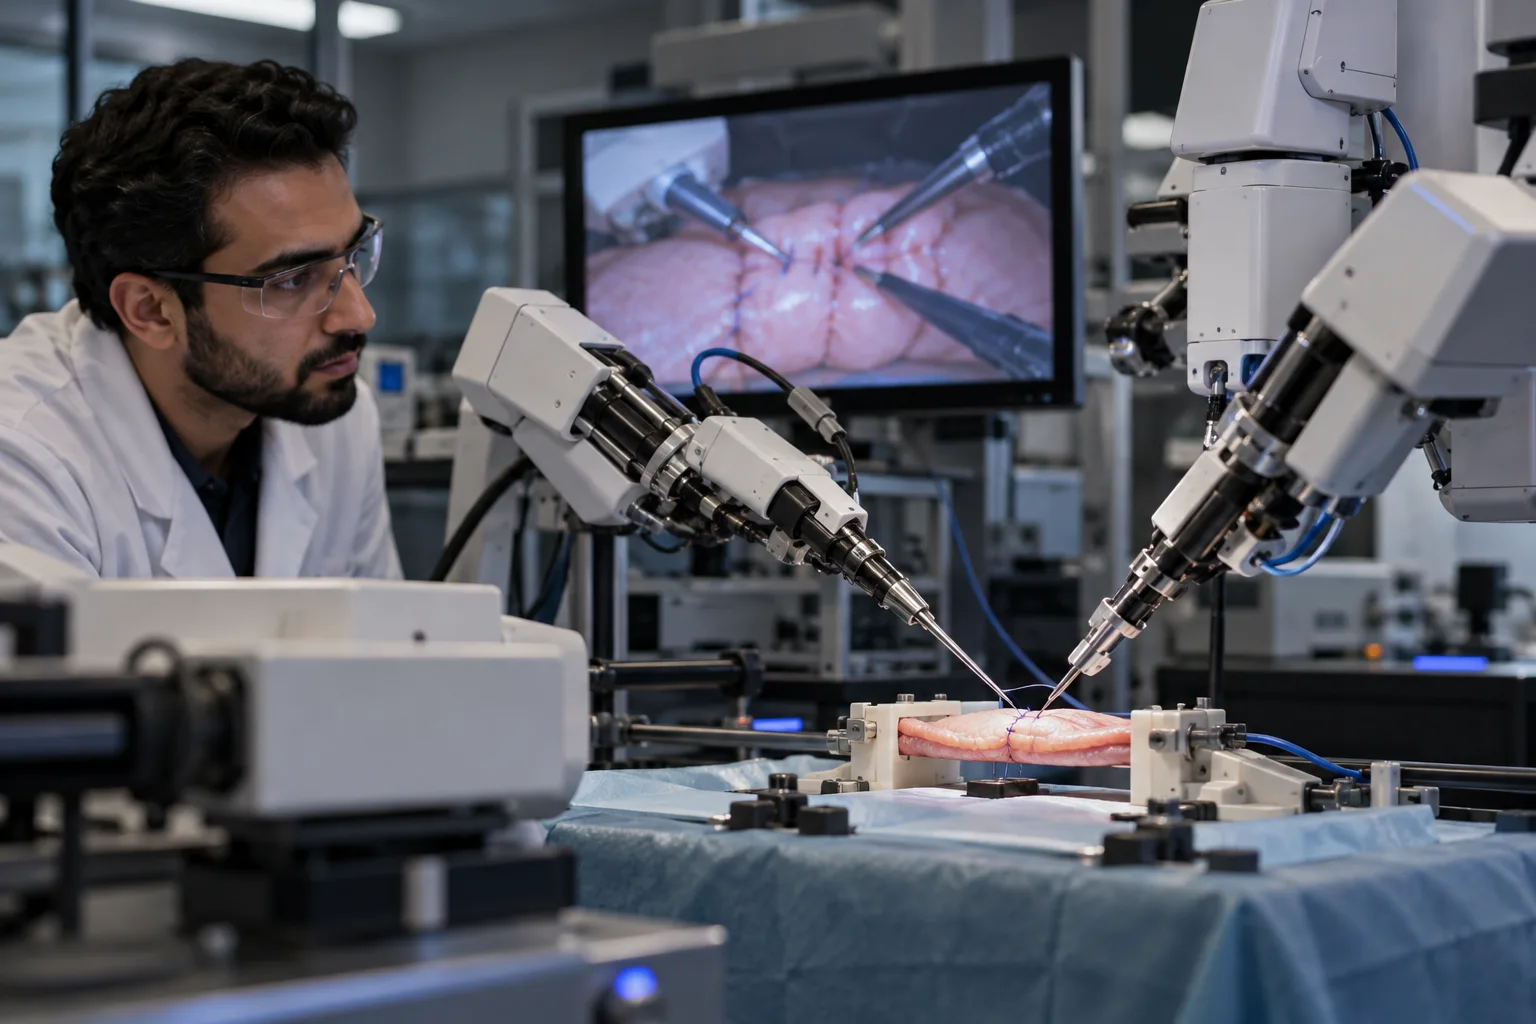
Robot performs gallbladder removal steps autonomously on eight ex vivo specimens
What was demonstrated
A hierarchical control framework (SRT-H) combined a high-level planner that issues task and corrective instructions in natural language with a low-level policy that generates robot trajectories, trained by imitation learning. In ex vivo cholecystectomy experiments it completed the targeted procedure steps with a 100% success rate across eight gallbladders, without human intervention.
Why it matters
Earlier autonomous surgery work mostly automated short tasks in controlled settings. This shows step-level autonomy over a long, dexterous procedure with recovery from errors.
Caveats
- Tested only on ex vivo tissue; no live animal or human surgery was performed.
- Sample size is eight specimens.
- Ex vivo set-ups lack bleeding, breathing motion and other complications of live surgery.
Technology profiles
Sources
- peer reviewed paper
SRT-H: A hierarchical framework for autonomous surgery via language-conditioned imitation learning
Ji Woong (Brian) Kim, Juo-Tung Chen, Pascal Hansen et al.. Science Robotics, 9 Jul 2025. DOI: 10.1126/scirobotics.adt5254.
Last reviewed 20 Oct 2026.